
센서 신호에서 판단까지, 한 흐름으로From raw signals to decisions — one pipeline
여섯 연구 분야는 센서 신호에서 시작해 차량·로봇 탑재까지 이어지는 하나의 인지 파이프라인을 이룹니다.Our six areas form one perception pipeline, from raw sensor signals to deployment on vehicles and robots.
레이더 데이터셋·신호 수준 AIRadar Datasets & Signal-Level AI
Radar Datasets & Signal-Level AI
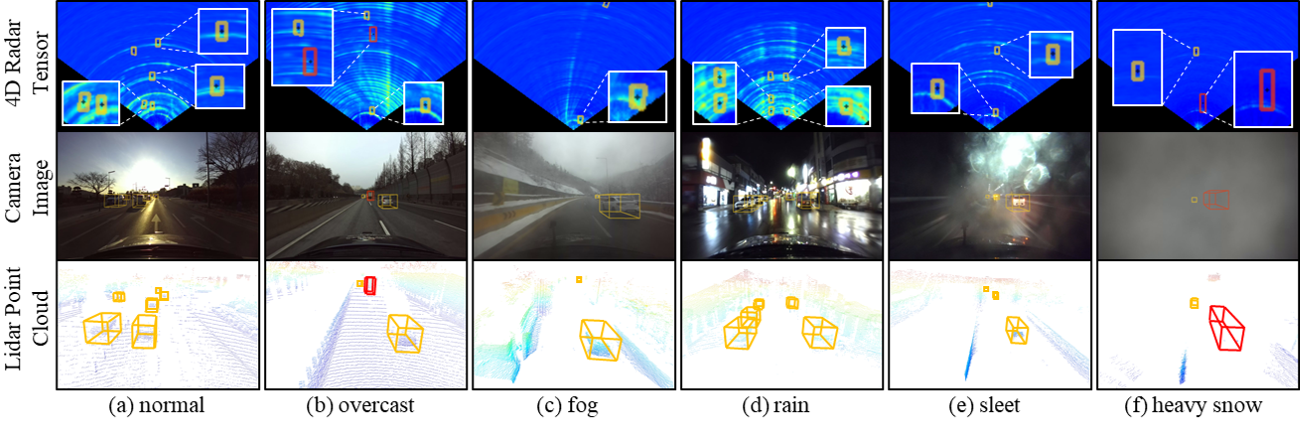
전 세계 70여 개 기관이 사용하는 K-Radar 데이터셋을 시작으로, LiDAR로부터 레이더 텐서를 합성하는 데이터 확장, 장면·과제 인지형 레이더 전처리(cognitive radar), 드론 레이더와 국방·치안 응용으로 연구를 확장합니다.Starting from K-Radar — used by 70+ institutions worldwide — we expand into LiDAR-to-radar tensor synthesis, scene- and task-aware cognitive radar preprocessing, and drone and defense radar applications.
- K-Radar
- Data Synthesis
- Auto-Labeling
- Cognitive Radar
- Drone Radar
4D 레이더 인지4D Radar Perception
4D Radar Perception
포인트 클라우드를 넘어 4D 레이더 텐서와 raw ADC 신호를 직접 입력으로 사용하는 딥러닝 구조를 연구합니다. 레이더 고유의 희소성·잡음·도플러 정보를 활용해 날씨와 조명에 강인한 3D 객체 검출 성능을 끌어올립니다.We design deep networks that consume 4D radar tensors and raw ADC signals directly, going beyond sparse point clouds. By exploiting radar-specific sparsity, noise, and Doppler cues, we push weather- and illumination-robust 3D object detection.
- 4D Radar Tensor
- Raw ADC
- 3D Object Detection
- Doppler
- RTNH
다중 센서 융합Multi-Modal Sensor Fusion
Multi-Modal Sensor Fusion
C + L + R
센서별 가용성(availability)을 고려한 융합 기법으로, 일부 센서가 가려지거나 고장 나도 성능이 급격히 무너지지 않는 인지 시스템을 만듭니다. 통합 표현 공간(canonical space), 스테레오 레이더, 비전-언어 모델과의 정렬까지 융합의 범위를 넓히고 있습니다.Availability-aware fusion keeps perception stable when sensors are occluded, degraded, or missing. We explore unified canonical feature spaces, stereo radar, and alignment of radar with vision–language models.
- Availability-aware Fusion
- Camera–LiDAR–Radar
- Canonical Space
- Robustness
- VLM Alignment
3D 점유 예측·장면 이해3D Occupancy & Scene Understanding
3D Occupancy & Scene Understanding
(Sparse)4D Radar
(Dense)
객체 단위 검출을 넘어 주행 공간 전체를 복셀 단위로 이해하는 3D semantic occupancy, 주행 가능 영역 검출, 레이더 기반 깊이 보완을 연구합니다. 레이더 데이터에 맞는 새로운 벤치마크와 라벨도 함께 구축합니다.Beyond object boxes, we model the whole drivable scene at voxel level — 3D semantic occupancy, drivable-area detection, and radar-guided depth completion — together with new radar benchmarks and labels.
- Semantic Occupancy
- Depth Completion
- Drivable Area
- Benchmark
다중 객체 추적·상태 추정Multi-Object Tracking & State Estimation
Multi-Object Tracking & State Estimation
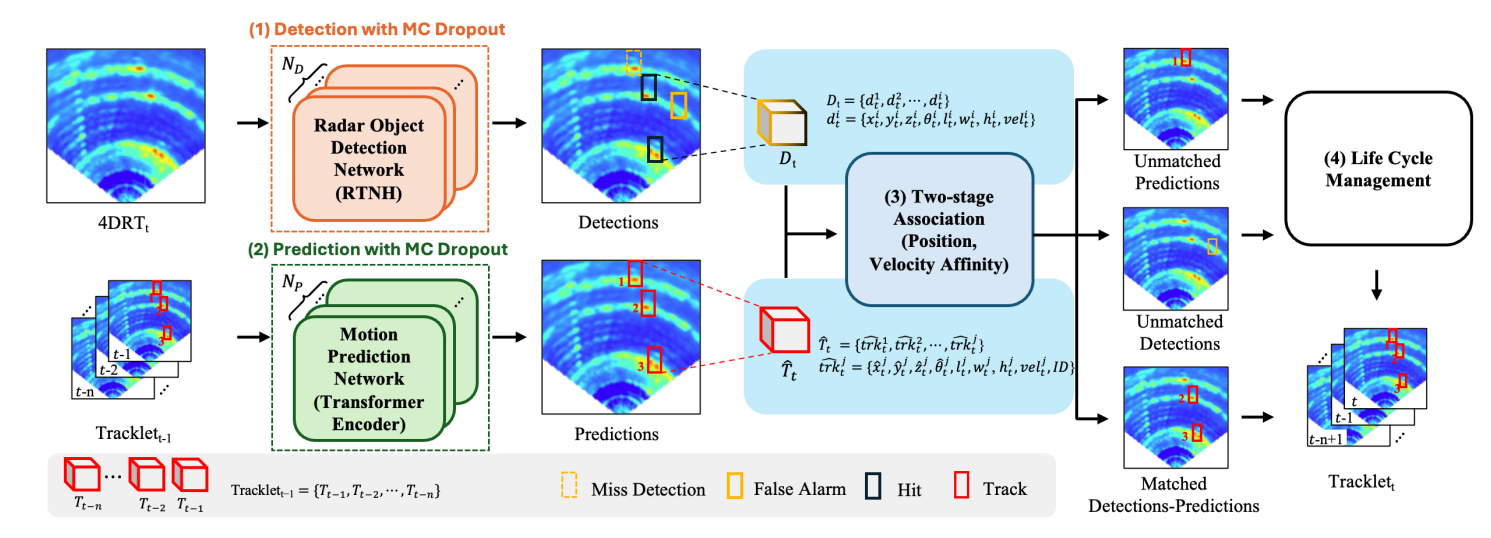
IMM, 칼만 필터 등 고전적 상태 추정 이론과 신경망을 결합해, 레이더의 속도 정보를 살린 다중 객체 추적과 불확실성을 고려한 궤적 예측을 연구합니다.We fuse classical state estimation (Kalman filters, IMM) with neural networks for radar-aware multi-object tracking and uncertainty-aware trajectory prediction.
- Kalman Filter
- IMM
- Bayesian Estimation
- Trajectory Prediction
- MOT
경량·뉴로모픽 임베디드 AIEfficient & Neuromorphic Embedded AI
Efficient & Neuromorphic Embedded AI
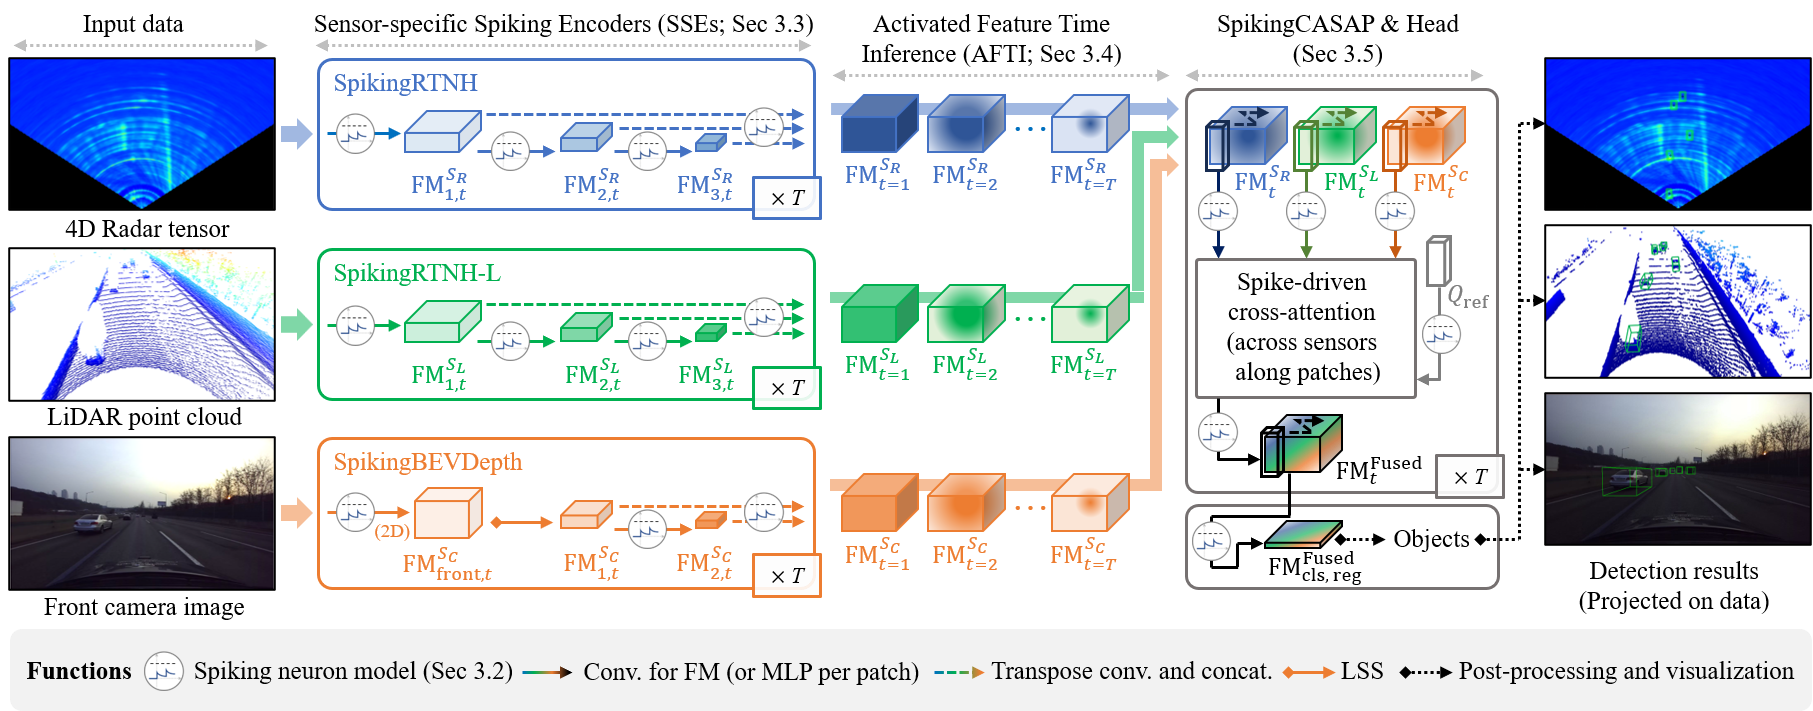
스파이킹 신경망(SNN) 기반 레이더 검출·센서 융합, NPU·Jetson 등 엣지 하드웨어 위 실시간 구현을 통해 차량·로봇·드론에 탑재 가능한 저전력 인지 시스템을 만듭니다.From SNN-based radar detection and fusion to real-time deployment on NPUs and Jetson-class edge hardware, we build low-power perception that fits on vehicles, robots, and drones.
- Spiking Neural Network
- On-Chip AI
- NPU
- Real-Time
- Edge Deployment