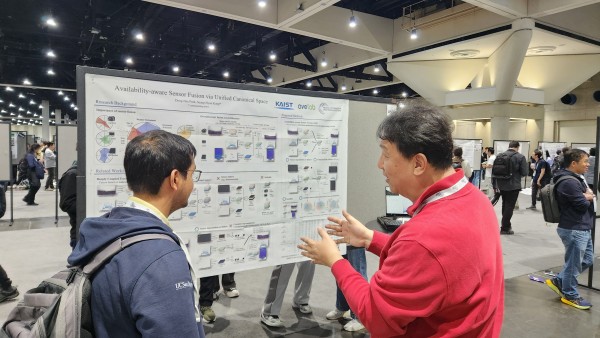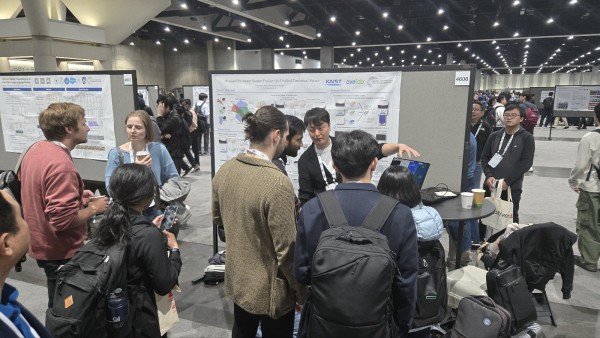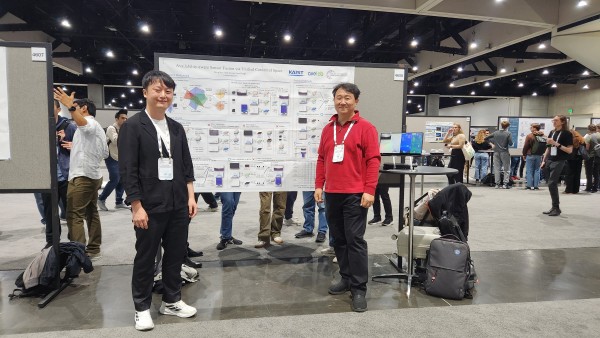
백동희 교수(당시 KAIST AVE Lab 박사후연구원)가 2025년 12월 5일 미국 샌디에이고에서 열린 NeurIPS 2025에서 논문 “Availability-aware Sensor Fusion via Unified Canonical Space”를 발표했습니다.
제안한 ASF(Availability-aware Sensor Fusion)는 카메라, LiDAR, 4D 레이더 각각의 가용성을 실시간으로 추정하고, 센서 상태에 따라 융합 비중을 자동으로 조절합니다. 덕분에 악천후나 센서 고장 상황에서도 주변 인지가 안정적으로 유지되며, 기존 최고 수준의 센서 융합 기법 대비 인지 정확도를 20% 이상 높였습니다. (arXiv)
원문: KAIST AVE Lab 소식 (2025.12.13)
On December 5, 2025, Prof. Dong-Hee Paek, then a postdoctoral researcher at KAIST AVE Lab, presented “Availability-aware Sensor Fusion via Unified Canonical Space” at NeurIPS 2025 in San Diego, USA.
The proposed ASF (Availability-aware Sensor Fusion) estimates in real time whether the camera, LiDAR, and 4D radar are available, and automatically adjusts their fusion weights. Perception stays stable in bad weather or under sensor failure, and recognition accuracy improved by more than 20% over the previous best sensor fusion methods. (arXiv)
Original post: KAIST AVE Lab News (Dec 13, 2025)