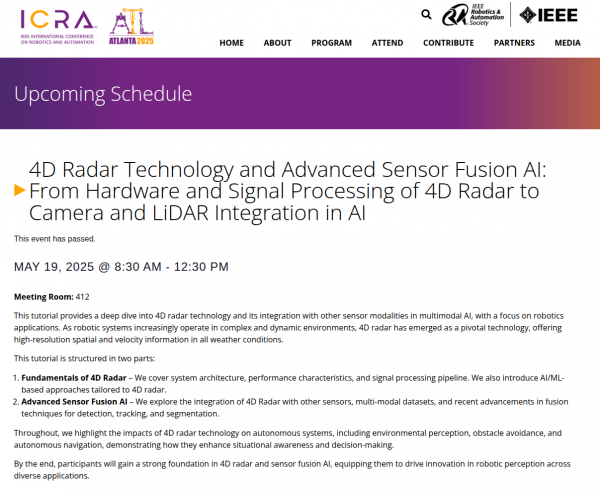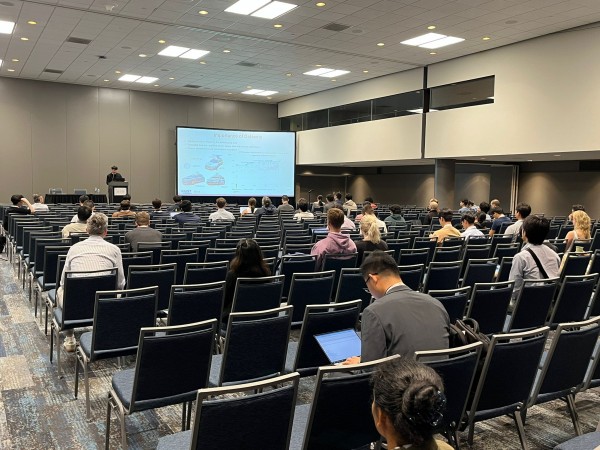
백동희 교수(당시 KAIST AVE Lab 박사과정)가 2025년 5월 19일 미국 애틀랜타에서 열린 IEEE International Conference on Robotics and Automation (ICRA) 2025에서 튜토리얼 “4D Radar Technology and Advanced Sensor Fusion AI: From Hardware and Signal Processing of 4D Radar to Camera and LiDAR Integration in AI”를 진행했습니다.
악천후와 복잡한 주행 환경에서도 강인한 인지를 제공하는 4D 레이더 기술과, 이를 바탕으로 한 멀티모달 센서 융합 AI를 이론적 기초부터 실제 적용 사례까지 폭넓게 다뤘습니다.
튜토리얼 자료: Courses › Tutorials
원문: KAIST AVE Lab 소식 (2025.05.28)
On May 19, 2025, Prof. Dong-Hee Paek, then a Ph.D. student at KAIST AVE Lab, gave the tutorial “4D Radar Technology and Advanced Sensor Fusion AI: From Hardware and Signal Processing of 4D Radar to Camera and LiDAR Integration in AI” at the IEEE International Conference on Robotics and Automation (ICRA) 2025 in Atlanta, USA.
The tutorial covered 4D radar, which keeps perception robust in bad weather and complex traffic, and the multimodal sensor fusion AI built on it, from theoretical foundations to practical applications.
Tutorial materials: Courses › Tutorials
Original post: KAIST AVE Lab News (May 28, 2025)