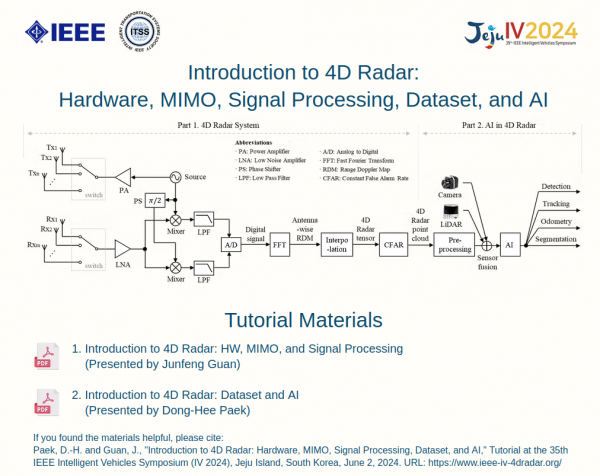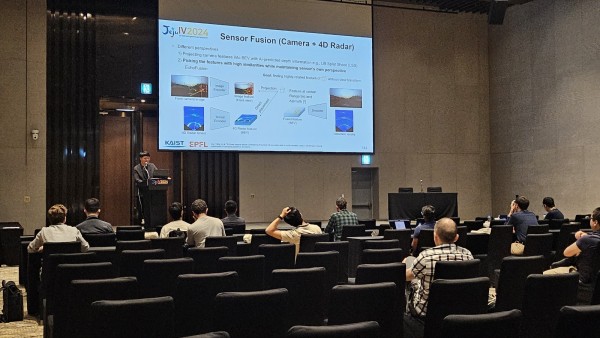
백동희 교수(당시 KAIST AVE Lab 박사과정)가 2024년 6월 2일 제주 신화월드에서 열린 IEEE Intelligent Vehicles Symposium (IV) 2024에서 튜토리얼 “Introduction to 4D Radar: Hardware, MIMO, Signal Processing, Dataset, and AI”를 EPFL의 Junfeng Guan 박사와 공동으로 진행했습니다.
- 세션 1 (Junfeng Guan 박사): FMCW 하드웨어, FFT 기반 거리·속도 추정, 도래각 추정과 2D 빔포밍, CFAR 검출, TDM MIMO 레이더의 도플러 위상 문제와 보상 기법
- 세션 2 (백동희): 4D 레이더 AI 연구 동향과 데이터셋. 직관적이지 않은 레이더 데이터 표현을 AI로 모델링하는 방법, 카메라·LiDAR와의 상호보완성을 고려한 센서 융합 네트워크, 레이더 신호 합성을 통한 학습 데이터 증강, 향후 연구 방향
튜토리얼 자료: Courses › Tutorials
원문: KAIST AVE Lab 소식 (2024.06.13)
On June 2, 2024, Prof. Dong-Hee Paek, then a Ph.D. student at KAIST AVE Lab, co-presented the tutorial “Introduction to 4D Radar: Hardware, MIMO, Signal Processing, Dataset, and AI” with Dr. Junfeng Guan of EPFL at IEEE Intelligent Vehicles Symposium (IV) 2024, Shinhwa World, Jeju.
- Session 1 (Dr. Junfeng Guan): FMCW hardware, FFT-based range and velocity estimation, angle-of-arrival estimation and 2D beamforming, CFAR detection, and Doppler phase issues in TDM MIMO radar
- Session 2 (Dong-Hee Paek): AI for 4D radar and datasets: modeling radar’s non-intuitive data representation, sensor fusion networks that exploit complementarity with camera and LiDAR, data augmentation by radar signal synthesis, and future directions
Tutorial materials: Courses › Tutorials
Original post: KAIST AVE Lab News (Jun 13, 2024)