
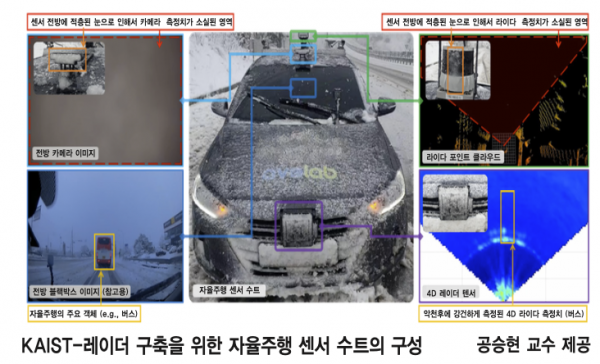
카이스트신문 제510호가 「악천후에서도 자율주행을 가능하게 하는 4D Radar 인공지능 기술」 기사로 K-Radar 연구를 소개했습니다.
기사는 카메라와 LiDAR가 눈·비와 오염에 취약한 반면, 4D 레이더는 악천후에서도 안정적으로 동작한다는 점에 주목했습니다. 약 35,000 프레임에 3D 박스 라벨을 단 13TB 규모의 데이터셋, 포인트 클라우드 대신 텐서를 사용한 설계, 그리고 기존 3D 레이더 대비 크게 향상된 검출 성능을 소개했습니다.
연구를 제1저자로 주도한 백동희 교수(당시 박사과정)는 인터뷰에서, 낯선 분야라 막막한 순간도 있었지만 지도교수님의 방향을 믿고 나아간 끝에 좋은 결과를 얻을 수 있었다고 소감을 전했습니다.
원문: KAIST AVE Lab 소식 (2022.11.01)
Issue 510 of the KAIST campus newspaper featured K-Radar in an article titled “4D radar AI that enables autonomous driving even in bad weather.”
The article highlighted that cameras and LiDAR struggle with snow, rain, and dirt, while 4D radar keeps working. It described the 13 TB dataset with about 35,000 frames of 3D box labels, the choice of radar tensors over point clouds, and detection performance well beyond earlier 3D radar.
In the interview, Prof. Dong-Hee Paek, who led the work as first author during his Ph.D., said the unfamiliar field brought moments of uncertainty, but trusting his advisor’s direction led to good results.
Original post: KAIST AVE Lab News (Nov 1, 2022)