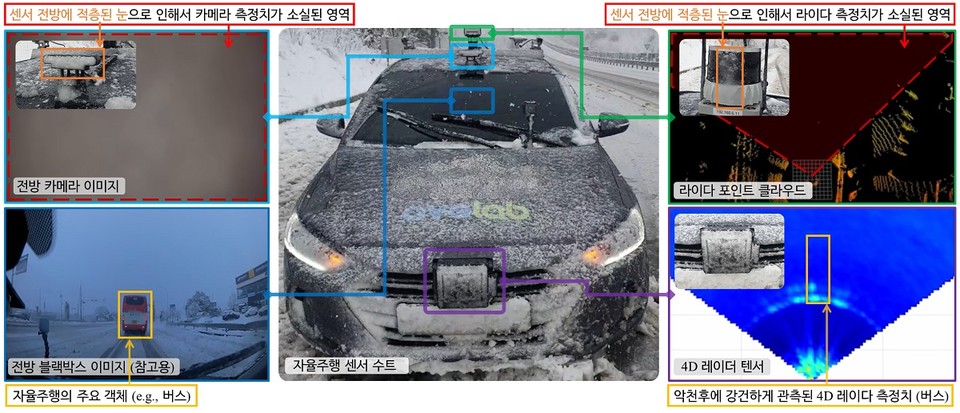
논문 “K-Radar: 4D Radar Object Detection for Autonomous Driving in Various Weather Conditions”가 세계 최고 수준의 AI 학회 NeurIPS 2022의 Datasets and Benchmarks Track에 게재되었습니다. 백동희 교수(당시 KAIST AVE Lab 박사과정)가 2022년 12월 학회에서 발표했습니다.
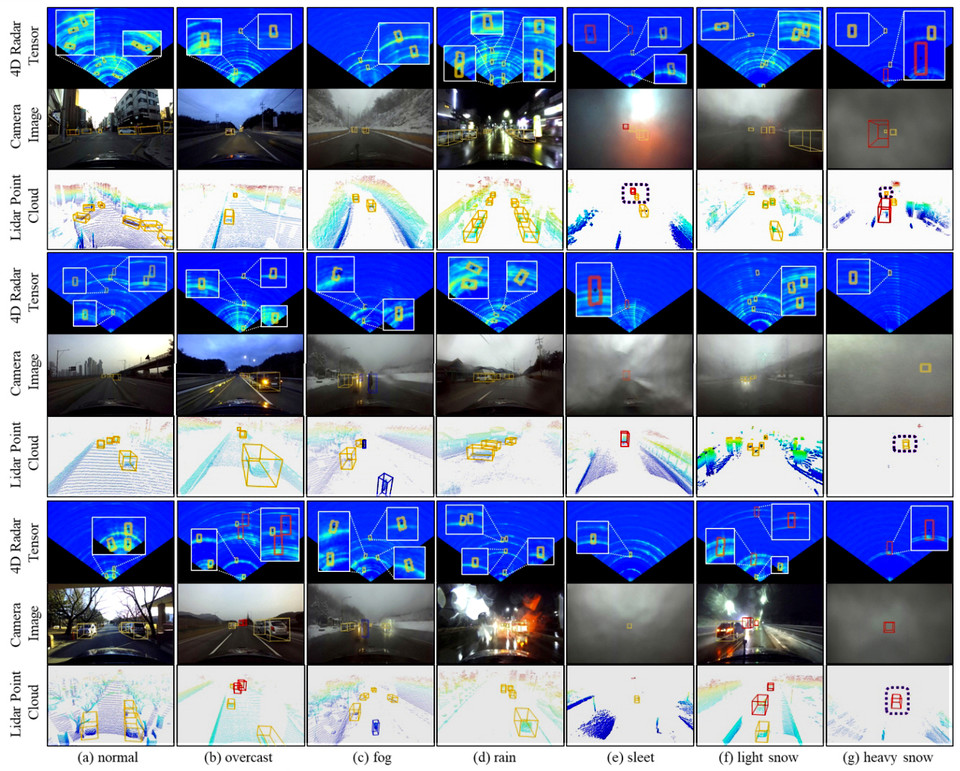
- 다양한 날씨와 교통 상황을 담은 약 13TB 규모의 4D 레이더 데이터셋을 카메라·LiDAR와 동기화해 공개
- 잡음 제거 과정에서 약한 신호가 사라지는 포인트 클라우드 대신, 원 신호를 보존하는 4D 레이더 텐서 형태로 제공
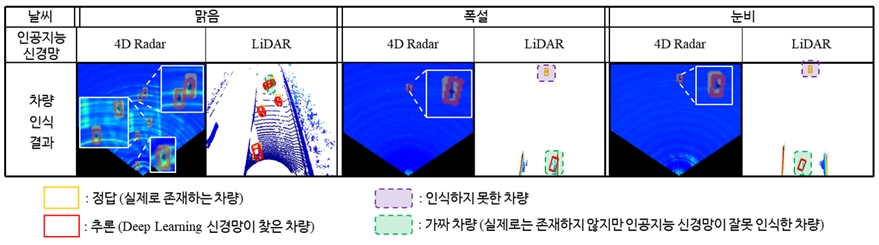
- 제안한 신경망은 날씨·도로 조건 전반에서 70m 이내 객체의 분류·위치·방향을 62.5% 정확도로 추정했고, 눈·비 속에서는 LiDAR 기반 네트워크보다 안정적인 성능을 보였습니다.
데이터셋, 네트워크, 개발 플랫폼과 벤치마크는 GitHub에 공개되어 있으며, YTN 사이언스·AI 타임스 등 여러 언론에 소개되었습니다. (arXiv)
원문: KAIST AVE Lab 소식 (2022.10.26)
The paper “K-Radar: 4D Radar Object Detection for Autonomous Driving in Various Weather Conditions” was accepted at the Datasets and Benchmarks Track of NeurIPS 2022. Prof. Dong-Hee Paek, then a Ph.D. student at KAIST AVE Lab, presented it at the conference in December 2022.
- About 13 TB of 4D radar data across diverse weather and traffic, synchronized with camera and LiDAR
- Released as 4D radar tensors rather than point clouds, preserving weak signals that denoising would remove
- The proposed network estimated class, position, and heading of objects within 70 m with 62.5% accuracy across conditions, and stayed more stable than a LiDAR-based network in snow and rain
The dataset, network, development platform, and benchmark are available on GitHub, and the work was covered by YTN Science, AI Times, and other outlets. (arXiv)
Original post: KAIST AVE Lab News (Oct 26, 2022)