
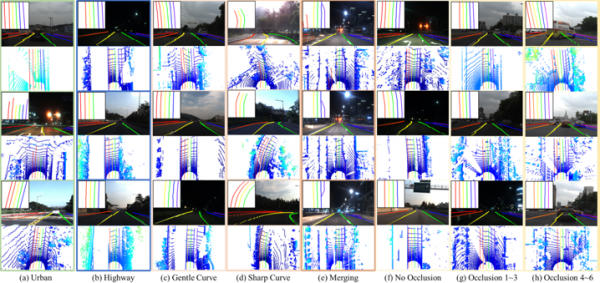
백동희, 공승현, Kevin Tirta Wijaya의 논문 “K-Lane: Lidar Lane Dataset and Benchmark for Urban Roads and Highways”가 IEEE/CVF CVPR 2022 Workshop on Autonomous Driving(WAD)에 게재되었습니다.
- K-Lane: 도심과 고속도로에서 주간·야간, 곡선 구간, 차선 가림 등 다양한 조건으로 수집한 15,000개 이상의 포인트 클라우드와 전방 카메라 영상으로 구성된 대규모 LiDAR 차선 인식 데이터셋
- LLDN-GFC: 전역 특징 상관(Global Feature Correlator)을 활용한 LiDAR 전용 차선 검출 네트워크로, CNN 기반 네트워크 대비 F1-score를 6.1%, 여러 차선이 가려진 상황에서는 10.2% 높였습니다.
데이터셋과 학습·평가·시각화·라벨링 도구는 GitHub에 공개되어 있습니다.
원문: KAIST AVE Lab 소식 (2022.04.18)
The paper “K-Lane: Lidar Lane Dataset and Benchmark for Urban Roads and Highways” by Dong-Hee Paek, Seung-Hyun Kong, and Kevin Tirta Wijaya was accepted at the IEEE/CVF CVPR 2022 Workshop on Autonomous Driving (WAD).
- K-Lane: a large-scale LiDAR lane dataset with more than 15,000 point clouds and front-camera images from urban roads and highways, covering day, night, curves, and occluded lanes
- LLDN-GFC: a LiDAR lane detection network with a Global Feature Correlator, improving F1-score by 6.1% over CNN-based networks and by 10.2% when multiple lanes are occluded
The dataset and tools for training, evaluation, visualization, and labeling are available on GitHub.
Original post: KAIST AVE Lab News (Apr 18, 2022)